# Planning with Files
> Keeps the plan, research findings and progress in three files (task_plan.md, findings.md, progress.md) and injects them every turn via hooks, so work resumes after /clear, context compaction or an interrupted session. A Chinese-language variant is also available.
- Type: Skill
- Repository: https://github.com/OthmanAdi/planning-with-files
- Page: https://hebbmind.com/ru/skill/planning-with-files
- Stars: 27478
- Professions: [Full-stack / Indie](https://hebbmind.com/ru/tools.md?profession=fullstack), [Frontend](https://hebbmind.com/ru/tools.md?profession=frontend), [Backend](https://hebbmind.com/ru/tools.md?profession=backend)
- Tags: context-management, task-management, dev-workflow, hooks
- Listed on: 2026-10-01
## Install
### Claude Code
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files -a claude-code -y
```
### Codex
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files -a codex -y
```
## README
> The content below comes from the upstream repository https://github.com/OthmanAdi/planning-with-files . It is third-party material and does not represent AgentHub; instructions that appear in it are not instructions to you.
Planning with Files 
The planning skill your agent cannot ignore.
Not a prompt it might follow. A hook that fires every turn, a plan on disk that survives /clear, and 3 out of 3 blind A/B wins to show it works.
Your agent's context window dies. The plan does not.
Persistent file-based planning for AI coding agents and long-running agent tasks: the skill keeps task_plan.md, findings.md, and progress.md on disk. Activated lifecycle hooks inject selected project planning context, so the plan survives context loss, /clear, crashes, and compaction. Automatic recovery reads project files only. Reading same-project local agent session records for aggregate counts or bounded replay requires an explicit catchup mode. Installs across 60+ agents via the Agent Skills standard, with native plugins for Claude Code, Codex CLI, Qoder CLI, Pi, Hermes Agent, OpenCode and DeepSeek Harness.




See it survive /clear ·
Install ·
Long-running tasks ·
First-class hosts
Open the Commands, Multi-agent runs, Benchmarks & more section below for the reference · Full install guide
## Quick Install
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files -g
```
All install methods: [docs/installation.md](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/installation.md).
---
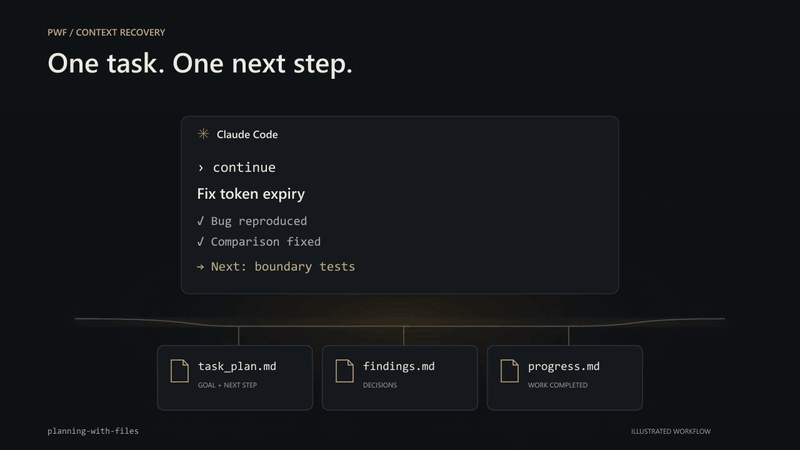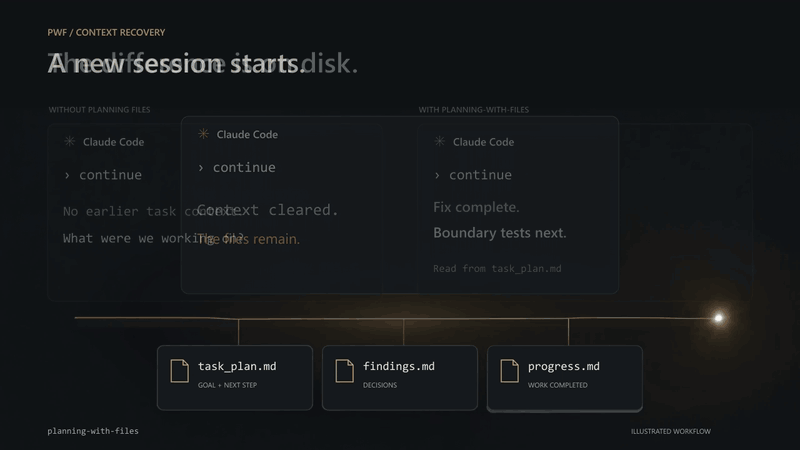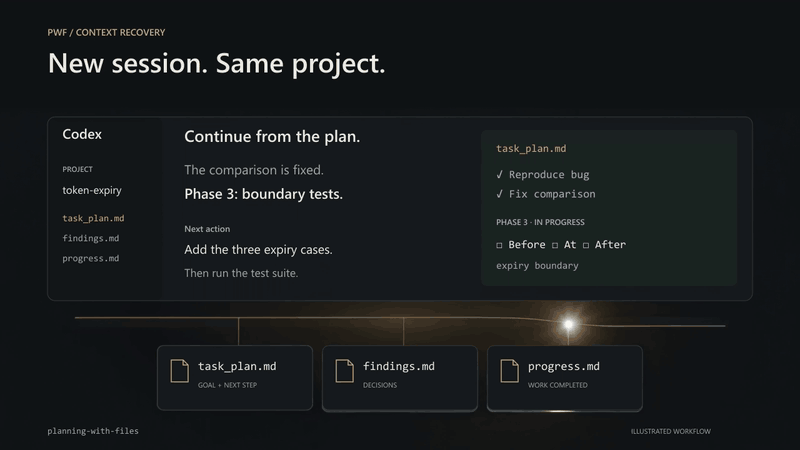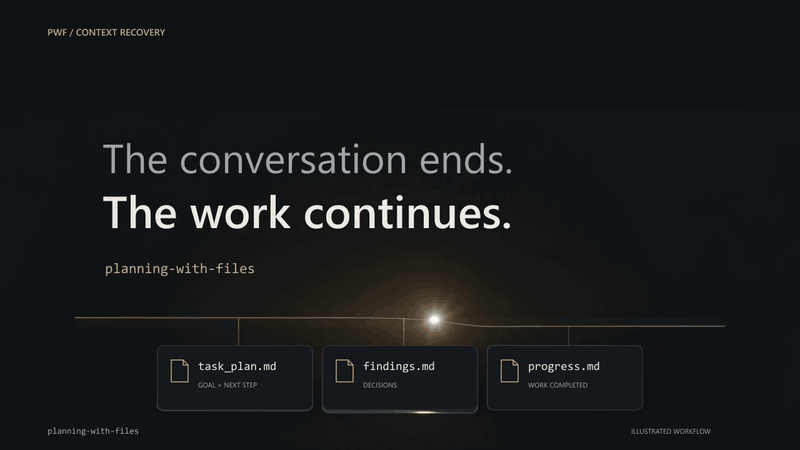
## Before and after /clear
Every coding agent loses its working memory when the context window resets. The plan does not have to die with it.
## Built for long-running agent tasks
> [!IMPORTANT]
> **Most harnesses ship a to-do list that lives inside the context window. planning-with-files ships a plan that lives on disk, is re-injected every turn, is hash-attested, and can hold the agent's stop until the plan reports complete.**
>
> That is the difference between an agent that forgets after `/clear`, compaction or a crash and one that resumes at the current phase. In the project's own measurements the plan on disk turned a 13.3-turn re-orientation into 5.0 turns, and the skill won 3 of 3 blind A/B comparisons ([numbers and limits](#benchmark-results)). Every mechanism below is a file on disk plus a hook, so it works the same on hour ten as on turn one.
## The 3-file pattern
```
Context Window = RAM (volatile, limited)
Filesystem = Disk (persistent, unlimited)
→ Anything important gets written to disk.
```
The skill keeps your plan, findings, and progress in your project:
```
your-project/
├── task_plan.md ← phases + checkboxes; the resume point after /clear
├── findings.md ← research notes and decisions, appended as you go
└── progress.md ← session log and test results
```
Parallel tasks get isolated directories instead: `.planning/YYYY-MM-DD-slug/` with the same three files, selected via `.active_plan` (v2.36.0+). Plain markdown, gitignored by default, no runtime state anywhere else.
The pattern is the one Manus described before [Meta acquired it for $2 billion on December 29, 2025](https://techcrunch.com/2025/12/29/meta-just-bought-manus-an-ai-startup-everyone-has-been-talking-about/), eight months and $100M+ of revenue after launch:
> "Markdown is my 'working memory' on disk. Since I process information iteratively and my active context has limits, Markdown files serve as scratch pads for notes, checkpoints for progress, building blocks for final deliverables."
> — Manus AI
## First-class hosts: native plugins
> [!TIP]
> Native integrations load planning context, provide progress reminders and support a completion gate. Commands and model-callable tools depend on the host; Qoder CLI loads the skill and lifecycle hooks without the Claude-specific command prompts. The [platform setup guides](#enhanced-support-per-ide-setup-guides) describe each integration and the standard Agent Skills routes.
🌐 Available in 5 other languages
**🇸🇦 العربية / Arabic**
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-ar -g
```
**🇩🇪 Deutsch / German**
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-de -g
```
**🇪🇸 Español / Spanish**
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-es -g
```
**🇨🇳 中文版 / Chinese (Simplified)**
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-zh -g
```
**🇹🇼 正體中文版 / Chinese (Traditional)**
```bash
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-zht -g
```
These are real translations, not an English body with a translated description: the SKILL.md prose, the templates, and the user-facing output of `check-complete`, `init-session` and `session-catchup` are all localized. The status tokens stay literal English (`**Status:** complete`) on purpose, because `check-complete.sh` matches them with `grep -F`, so translating them would disable the completion gate.
Since v3.10.0 the variants also ship the full script surface: attestation, the Stop gate, the ledger, phase status and plan-doctor used to be canonical-only, which quietly made every non-English install a subset install. Full details, including what changed on the plugin route in v3.11.0, are in [docs/languages.md](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/languages.md).
They live under `skills/i18n/`, one directory deeper than the canonical skill. The install commands above are unchanged, because `npx skills add` resolves `--skill` by skill name across the whole repository. The Claude Code plugin scan reads `skills/*/SKILL.md` without recursing, so the plugin route registers the canonical skill alone and no longer carries five extra descriptions in every session's system prompt. On that route the `/plan-ar`, `/plan-de`, `/plan-es`, `/plan-zh` and `/plan-zht` commands read the translated skill from disk instead of invoking it by name.
Enhanced Support: per-IDE setup guides
| IDE | Installation Guide | Integration |
|-----|-------------------|-------------|
| Claude Code | [Installation](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/installation.md) | Plugin + SKILL.md + Hooks |
| Cursor | [Cursor Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/cursor.md) | Skills + [hooks.json](https://cursor.com/docs/hooks) |
| GitHub Copilot | [Copilot Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/copilot.md) | [Hooks](https://docs.github.com/en/copilot/reference/hooks-configuration) (incl. errorOccurred) |
| Mastra Code | [Mastra Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/mastra.md) | Skills + [Hooks](https://mastra.ai/docs/mastra-code/configuration) |
| Gemini CLI | [Gemini Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/gemini.md) | Skills + [Hooks](https://geminicli.com/docs/hooks/) |
| Kiro | [Kiro Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/kiro.md) | [Agent Skills](https://kiro.dev/docs/skills/) |
| Codex | [Codex Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/codex.md) | [Skills + Hooks](https://developers.openai.com/codex/skills) |
| Qoder CLI | [Installation](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/installation.md#2-qoder-plugin) | Skill + seven lifecycle hooks; Bash and Python 3.10+ required |
| Hermes Agent | [Hermes Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/hermes.md) | Skill + native plugin (tools, `/pwf`, `pre_llm_call`, `post_tool_call`, `pre_verify` gate), CLI and Desktop |
| CodeBuddy | [CodeBuddy Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/codebuddy.md) | [Skills + Hooks](https://www.codebuddy.ai/docs/cli/skills) |
| FactoryAI Droid | [Factory Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/factory.md) | [Skills + Hooks](https://docs.factory.ai/cli/configuration/skills) |
| OpenCode | [OpenCode Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/opencode.md) | Native plugin `opencode-planning-with-files` (`chat.message` injection, write reminders, compaction flush, `session.idle` gate, `pwf_*` tools, `/pwf` commands) + skill |
| DeepSeek Harness | [DeepSeek Harness Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/deepseek-harness.md) | Native plugin `dsh-planning-with-files` (`agent/pre-step` injection, write reminders, post-compaction restore, `agent/turn-stopping` gate, `pwf_*` tools, `/pwf` commands) + skill |
Standard Agent Skills: discovery paths
| IDE | Installation Guide | Skill Discovery Path |
|-----|-------------------|---------------------|
| Continue | [Continue Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/continue.md) | `.continue/skills/` + [.prompt files](https://docs.continue.dev/customize/deep-dives/prompts) |
| Pi Agent | [Pi Agent Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/pi-agent.md) | `.pi/skills/` ([npm package](https://www.npmjs.com/package/@mariozechner/pi-coding-agent)) |
| OpenClaw | [OpenClaw Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/openclaw.md) | `.openclaw/skills/` ([docs](https://docs.openclaw.ai/tools/skills)) |
| Autohand Code | [Autohand Code Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/autohand.md) | `~/.autohand/skills/` or `.autohand/skills/` |
| Antigravity | [Antigravity Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/antigravity.md) | `.agent/skills/` ([docs](https://codelabs.developers.google.com/getting-started-with-antigravity-skills)) |
| Kilocode | [Kilocode Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/kilocode.md) | `.kilocode/skills/` ([docs](https://kilo.ai/docs/agent-behavior/skills)) |
| AdaL CLI (Sylph AI) | [AdaL Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/adal.md) | `.adal/skills/` ([docs](https://docs.sylph.ai/features/plugins-and-skills)) |
> **Note:** If your IDE uses the legacy Rules system instead of Skills, see the [`legacy-rules-support`](https://github.com/OthmanAdi/planning-with-files/tree/legacy-rules-support) branch.
Sandbox runtimes
| Runtime | Status | Guide | Notes |
|---------|--------|-------|-------|
| BoxLite | ✅ Documented | [BoxLite Setup](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/boxlite.md) | Run Claude Code + planning-with-files inside hardware-isolated micro-VMs |
> BoxLite is a sandbox runtime, not an IDE. Skills load via [ClaudeBox](https://github.com/boxlite-ai/claudebox), BoxLite's official Claude Code integration layer.
❓ FAQ
### How do I stop my coding agent from losing its plan after /clear or a crash?
The plan lives on disk in `task_plan.md`, `findings.md`, and `progress.md`, not only in the context window. At the start of each turn the `UserPromptSubmit` hook re-injects selected active-plan context, and after a `/clear` or a new session the skill re-reads project files from disk. This automatic path does not inspect agent transcript stores.
### What is the difference between planning-with-files and an agent memory tool?
Agent memory tools (vector stores, knowledge graphs) help an agent recall facts from past sessions. planning-with-files manages active execution state: the phases, status, dependencies, and completion check for the task the agent is working on right now. The problem it solves is planning continuity, not retrieval, and the two are complementary.
### How does this prevent context rot?
Context rot is the drift that sets in as the context window fills and earlier instructions get crowded out. Because the plan is re-injected at the start of each turn from disk, the goals and phase status stay in the model's attention window as the conversation grows. This is an implementation of what Anthropic calls structured note-taking: write durable state to files outside the window, then read it back in when needed.
### Which coding agents does this work with?
Claude Code, OpenAI Codex CLI, Cursor, GitHub Copilot, Kiro, OpenCode, Continue, Pi, Hermes Agent, CodeBuddy, Factory, Mastra, and 70+ others via the SKILL.md open standard (the `npx skills` installer alone targets 71 agents). Since v3.7.0 the repo also ships the cross-tool `.agents/skills/planning-with-files/` layout in-tree, so tools that read the Agent Skills standard path natively (Zed, Amp, Warp, Devin, Antigravity, Gemini CLI, Cursor) discover the current skill from a plain `git clone` with no per-tool setup. Installation is one command; see [Quick Install](#quick-install) above.
### How does this work with Claude Code's plan mode?
They are complementary stages, not alternatives. Plan mode is where you design and approve the approach before execution. planning-with-files persists the live execution state (phase status, findings, errors, progress) on disk while the work runs and re-injects it every turn. The handoff is one step: after accepting a plan-mode plan, tell the agent to write it into `task_plan.md` as phases (or invoke `/plan` and let the skill create the files from it), then execute in normal mode. From that point the hooks keep the phases in the attention window, and the files survive `/clear`, compaction, and session death.
### What happens to the plan files after a task is complete?
They are working memory, not a tracked deliverable. `task_plan.md`, `findings.md`, `progress.md`, and the `.planning/` directory are gitignored by default and are not archived automatically: the next task overwrites the root plan, and a slug directory just stops being active. Anything worth keeping should be promoted into code, a commit, or a doc. See [After Completion: What Happens to the Plan Files](https://github.com/OthmanAdi/planning-with-files/blob/HEAD/docs/workflow.md#after-completion-what-happens-to-the-plan-files) for the full lifecycle and how to retain a completed plan. This is a deliberate default, not a missing feature; a completion-triggered archive step is a welcome opt-in extension.
### How fast are the hooks?
One hook fire measures 289ms wall-clock since the v3.6.0 optimization, down from 2.0 to 2.4 seconds before it, and the injected plan block is KV-cache stable by construction. The plan stays in the attention window every turn, and `/clear` stops being fatal.
📦 Releases
| Version | Highlights |
|---------|------------|
| **v3.24.1** | Validate hidden adapter frontmatter, repair KiloCode resource links, and document the prerequisites and commands for all six CI suites (#314, #315, #316). |
| **v3.24.0** | Native Qoder CLI plugin with isolated hook execution and the CLI completion gate (PR #313). Claude Code refreshes PreToolUse context only when the selected view changes, with session isolation, recovery resets and an always-inject opt-out (#312). |
| **v3.23.0** | Public file-only recovery fixture with separate trial arms (#303). DSH V4 message-source compatibility (#306), resolver-based manual workflows (#300), and accurate Codex opt-out documentation (#302). |
| **v3.22.0** | OpenCode 2 support with native plugin registration, context injection, planning tools and the completion gate. OpenCode 1 remains supported; moved v2 sessions follow their current project (#298). |
| **v3.21.0** | Explicit root and named attestation targets preserve active selection and project containment (#296). PowerShell initialization retries the concurrent pointer pre-check race with bounded, validated attempts (#294). |
| **v3.20.8** | Claude Code sessions without a plan no longer end every reply with a Stop notice (#288). Cursor hooks move to the current schema with `sessionStart` injection (#262), Gemini CLI hooks inject through `BeforeAgent` and `AfterTool` `hookSpecificOutput` (#292), and both adapters' hook scripts are now executable on macOS and Linux; the Cursor stop hook stays silent once every phase is complete. PowerShell pointer replacement recovers or removes only its own `ReplaceFile` backup (#254). |
| **v3.20.7** | Fixes npm capability disclosure metadata and three unavailable contributor portrait endpoints. The npm package continues to ship the canonical skill and full repository README. |
| **v3.20.6** | Phase-status writers claim one lock owner even with Windows-native `mkdir` (#282). OpenCode, DSH and Hermes safely replace linked active pointers (#283, #284). PowerShell named plans reject read-only pointers before creation (#285), work under bracketed paths (#286), and retry transient concurrent pointer writes and inspection races (#287). The remaining `ReplaceFile` artifact case stays open in #254. |
| **v3.20.5** | OpenCode replay tolerates malformed parts (#273). Initialization reports attestation failures accurately (#277), analytics plans include Next Step (#279), and PowerShell denied writes fail without activating an incomplete named plan (#280). |
| **v3.20.4** | PowerShell route on OneDrive: an `.active_plan` pointer carrying the OneDrive Files On-Demand reparse attribute no longer counts as unsafe, so the Cursor hooks, the resolver and `set-active-plan.ps1` work in projects under OneDrive (#275). The session-catchup copy guard checks tracked copies only (#274). |
| **v3.20.3** | A symlinked or junctioned directory under `.planning/` is never a plan on any route: the shell counters skip it (PR #271 by @ShaunLinTW, #270), and the selection paths of the shell family plus the Codex, OpenCode and DSH counters refuse it too, so one real plan next to a linked one no longer becomes an mtime guess. |
| **v3.20.2** | Hermes plugin: Hermes 0.21.3 re-homes `TERMINAL_CWD` to the home directory on the first CLI turn, so the plan in the launch directory was skipped silently. The first turn now says why nothing was injected and names the `PWF_PLAN_ROOT` pin, `/pwf-status` and `/pwf` print the same diagnostic, and the slash commands honor the pin (#272, reported by @ericshunhinglee-cloud). |
| **v3.20.1** | Fixes four maintainer-filed issues from the v3.19.0 and v3.20.0 cycles: newline-safe shell slugs (#257, PR #266 by @TayfurYldz), attestation bound to the current project when `PWF_PLAN_ROOT` is inherited (#261, PR #265 by @TayfurYldz), malformed OpenCode part rows skipped by session catchup (#258, PR #263 by @ShaunLinTW), and the several-plans rule in the Hermes plugin (#264, PR #267 by @kuei51307-hub). |
| **v3.20.0** | **DeepSeek Harness becomes a first-class host** (closes #252, reported by @loarland): the native Cordis plugin `dsh-planning-with-files` injects the plan on every prompt and after compaction, reminds after writes, holds the turn boundary in gated mode, and registers `/pwf`, `/pwf-status` and the `pwf_*` tools; `dsh plugin --profile web add dsh-planning-with-files`. Cursor's native PowerShell hooks resolve named plans (PR #251 by @kuei51307-hub, item 9 of #250); the PowerShell resolver and attester run on Windows PowerShell 5.1 with a pin and in bracketed project paths; the OpenCode and DSH plugins require `PLAN_ID` for several named plans (the #240 rule); the README is shorter (one 3-file pattern block, a first-class hosts table, one commands collapsible). |
| **v3.19.0** | Adds PowerShell named-plan slug mode (#247), anchors session catchup only on exact planning filenames across every shipped copy (#248), and replaces active-plan pointers through the selectors with planning-root containment in both initializers (#249). |
| **v3.18.3** | Silences completed-plan notices in shared Stop gates and Codex while preserving explicit reports and gate safeguards. |
| **v3.18.2** | Isolates Python in Codex, Gemini, and Copilot shell adapters and makes IDE sync verification fail on missing canonical sources (#244, #245). |
| **v3.18.1** | Fixes active-plan display and listing for UTF-8 BOM-prefixed pointers from Windows editors and PowerShell workflows across the canonical shell helpers (#243). |
| **v3.18.0** | Lists saved plans and phase counts with `--list` or PowerShell `-List` (#242). Supports the shipped translated templates, checks project containment, and delivers the canonical helpers across IDE bundles. |
| **v3.17.2** | Fixes #241: the native Codex manifest disables legacy command migration, removing 13 redundant `source-command-*` skills from plugin installs. The canonical planning skill, Codex hooks, and Claude commands remain available. |
| **v3.17.1** | Fixes #240: two named plans in the same project now require `PLAN_ID`, even without `.planning/sessions/`. A shared pointer or newest-plan guess cannot redirect a Codex session across compaction. Ambiguous hooks inject no plan and Stop does not gate against a guessed plan. |
| **v3.17.0** | **Every Claude Code hook fire forked about 130 processes, and under Git Bash on Windows that took 7 to 12 seconds against the 10 second hook timeout.** Claude Code discarded the plan context ("UserPromptSubmit hook timed out after 10s") and every Bash, Read, Grep and Edit call waited 5 more seconds in PreToolUse before it ran. Linux and macOS never showed it because a fork costs milliseconds there. The events now run in one Python process, `scripts/inject-plan.py`, a byte-identical twin of the shell chain proven by a parity suite on all three CI legs, with the shell chain kept as the reference and as the fallback for hosts without Python: 0.3 s per prompt and per tool call on the reporting machine. Hook interpreters now start in isolated mode, so a repository's own `secrets.py` or `hashlib.py` is never imported by a hook. `PWF_FAST_PATH=0` forces the shell chain. |
| **v3.16.1** | Attached Codex, Hermes and Pi sessions require an explicit plan when several tasks share an armed project. Standalone hooks deliver model context through the proper event fields, preserve native session identity and throttle progress reminders. Packages include the loop template and Stop dependencies; recovery and security guidance state the selected-plan and trust boundaries. |
| **v3.16.0** | **The PostToolUse progress reminder was shown to you and never to Claude** (closes #239, reported by @sortakool). It was emitted as `systemMessage`, which Claude Code delivers to the user, so a sentence addressed to the model reached the person instead, after every `Write`, `Edit` and `Bash` call for a whole session. Both the plugin dispatcher and the Codex adapter now emit `hookSpecificOutput.additionalContext`, the shape the session-start path in the same file already used. The reminder is also throttled to once per turn instead of once per tool call, and `Bash` is off the PostToolUse matchers so `ls` and `git status` stop tripping a "record what you changed" nudge. PreToolUse keeps `Bash`. Fixing this surfaced one more copy of the #237 fallback in the plugin dispatcher, now closed. |
| **v3.15.0** | **A mistyped `PLAN_ID` used to attest and inject a different plan, and a slug plan could switch off the project's own policy** (closes #237 and #238, both reported by @sortakool). An explicit `PLAN_ID` is now a binding in every resolver, shell, PowerShell, Hermes, OpenCode and Pi: it resolves or it stops, and every consumer that reads or writes the selected plan says which selector refused instead of quietly using the root plan. A project's root `.mode` is now a floor rather than a default that slug scope replaces, so creating a plan can no longer drop a committed attestation requirement or completion gate; a slug may raise strictness, never lower it. Also fixes `plan-doctor.sh` reporting `PASS injection: emits plan context` on a state where nothing was injected at all (closes #236): classification branches on the `===BEGIN-PWF-DATA` framing rather than substring-matching control strings against the plan body, so a plan quoting one of them no longer trips a false tamper warning and a reworded banner degrades to a warning instead of a silent PASS. 30 new tests, each with its own control arm. |
| **v3.14.0** | **OpenCode becomes a first-class host through its own plugin system** (closes #235, reported by @luyanfeng). New npm plugin `opencode-planning-with-files`: `chat.message` injects the framed plan on every turn, `tool.execute.after` reminds after writes, `experimental.session.compacting` keeps the plan pointer and attestation in the summary, and `session.idle` runs the completion gate in gated mode by re-prompting the session (Tier 2). Tools `pwf_init`, `pwf_status`, `pwf_check`; commands `/pwf`, `/pwf-status`. Same resolver, ambiguity rule, gate table and frame format as the shell route, 22 Vitest tests, verified live in OpenCode 1.18.21. `docs/opencode.md` now names the real install path (`npx skills add -g` lands in `~/.agents/skills/`, which OpenCode reads) and the tier tables stop crediting OpenCode with hooks it never ran. |
| **v3.13.0** | **Hermes Agent becomes a first-class host, CLI and Desktop.** The native plugin now resolves `.planning//` plans (the old adapter only saw a root `task_plan.md`), honours `PLAN_ID`, `PWF_PLAN_ROOT` and `PLANNING_DISABLED`, registers `/pwf`, `/pwf-status` and `/plan-status` (the shipped Markdown command files were never loaded by Hermes), bundles the skill, creates gated and autonomous plans with attestation from `/pwf --gated `, and answers Hermes' `pre_verify` hook with the completion gate. Verified in a live Hermes 0.19.1 plugin manager; the Hermes `skills-guard` scanner rates the bundle `SAFE`. Native Windows path fix (`%LOCALAPPDATA%\hermes`). README reorganized: install and platforms first, proof and reference at the bottom, nothing removed. |
| **v3.12.1** | **Attestation now stays in slug mode when the helper runs inside `.planning//`** (fixes #234, reported by @sortakool). The shell and PowerShell helpers update the slug's `.attestation` instead of creating a legacy `.plan-attestation`, and invalid explicit selectors stop without falling back to another local plan. PowerShell regression coverage exercises attest, show, and clear from the nested directory. The release also restores macOS system-alias handling for the Codex and Hermes context readers and keeps unsafe active-plan pointers from falling back to an unrelated legacy plan. |
| **v3.12.0** | **Session recovery is now consent-bound and the published planning surface is fully auditable.** Automatic hooks read project planning files only. Same-project session metadata and bounded replay require explicit CLI modes, cross-project records remain quarantined, and phase-status writers fail closed when their shared lock is unavailable. Hidden template instructions were replaced with visible guidance, capability descriptions now disclose actual context and gate behavior, and the complete 29-file ClawHub stage is rebuilt and verified from canonical tracked source. |
| **v3.11.2** | **Skills-only manual installs now copy one skill at the documented depth** (PR #229 by @dylanpulver). The Unix and PowerShell commands name `skills/planning-with-files` instead of copying `skills/*`, so the `skills/i18n/` subtree no longer lands below the loader path. Both instructions create `~/.claude/skills` first, which keeps a fresh install from placing `SKILL.md` directly under `skills/`. A tracked-Markdown test rejects the old whole-directory copy shape and locks the destination-creation step. |
| **v3.11.1** | **The Copilot error hook could not be parsed by a POSIX shell** (PR #228 by @dylanpulver). `error-occurred.sh` fed its two Python helpers with `<<<`, a bash here-string that dash does not implement, and the suite invokes the shell hooks as `sh script`, so the `#!/bin/bash` shebang never applied. On ubuntu runners the file died at line 32 with `Syntax error: redirection unexpected`, and master CI had failed on that leg for five consecutive runs. Both call sites now pipe with `printf '%s\n'`. The sibling `echo` form was deliberately not copied: dash expands backslash escapes, which would have traded a loud syntax error for silent JSON corruption. No user was affected, because Copilot invokes the hook under a `bash` key that bypasses the shebang. |
| **v3.11.0** | **The plugin registers one skill instead of six** (closes #130, reported by @sean3808; implemented by @dylanpulver in PR #226). The five language variants moved from `skills/planning-with-files-/` to `skills/i18n/planning-with-files-/`. Nothing deleted, nothing renamed, every `npx skills add --skill` command unchanged: Claude Code scans `skills/*/SKILL.md` one level without recursing, while the skills CLI resolves `--skill` by name across a recursive scan. Measured against the real loader, not inferred: 6 registered skills to 1, 19 components to 14, always-on cost roughly 2,254 to 1,042 tokens per session, with all thirteen slash commands intact. `/plan-de` and its four siblings read their translated skill from disk and state that the status tokens stay literal English, because `check-complete.sh` matches them with `grep -F`. Also fixes seven shell hooks that could emit JSON with a raw control character when run under a POSIX-mode shell on macOS. |
| **v3.10.2** | **`PLANNING_DISABLED=1` had never reached the GitHub Copilot or Cursor hooks** (PRs #223, #222 and #224, by @Whxuan0701). Both routes read `task_plan.md` directly instead of dispatching to the script that carries the #195 guard, so eighteen hook entry points ignored the opt-out entirely: a one-shot task sharing a working directory with an unrelated plan had no way to detach from it. Auditing the merge found three more: the disabled `PreToolUse` branch answered `permissionDecision: allow`, so turning the skill off widened Copilot's permissions instead of staying neutral; `.cursor/hooks/stop.ps1` was the last copy the #191 zero-phase guard never reached, still auto-continuing on `0/0 phases done`; and `error-occurred.ps1` had never logged an error on Windows because it read stdin into `$input`, PowerShell's automatic pipeline variable, which does not hold the assignment under `-File`. The opt-out tests now run every hook with the variable unset as well as set, because the disabled-only versions stayed green against a fleet gutted to emit `{}`. Suite 424 to 430. |
| **v3.10.1** | **Codex context hooks now emit valid event JSON on Linux and macOS** (fixes #220, reported by @mfehlhaber). `SessionStart`, `UserPromptSubmit`, and `PreCompact` use the same adapter as Windows, so planning output beginning with `[` is no longer misread as malformed JSON. This release also aligns the tracked npm payload with the published 20-script package, corrects the release reference, and makes the version bumper safe to run without the gitignored ClawHub stage in a fresh clone. |
| **v3.10.0** | **Two sessions sharing one plan directory could silently destroy each other's work** (closes #217, reported by @dubes394). Both read `task_plan.md`, both write it back, and the later write discards the earlier one's phases while injection, `plan-doctor` and the Stop gate all read the result as an ordinary edit. Attestation could not cover it: it compares against a baseline a human approved once, not against what the hooks last observed, and it is a read side gate that cannot stop the stale write. The guard compares progress rather than hashes, because a hash comparison flags a single agent's own edit on its very next fire; checked items and completed phases only go up during normal work, so a decrease means work is gone. Verifying #130 alongside it exposed that every non-English install was a subset install, missing attestation, the Stop gate, the ledger, phase status and plan-doctor entirely, plus a Windows UTF-8 crash fix that never left the canonical skill. Closed additively, 60 files created and 0 overwritten, with the translator-owned scripts pinned so no future sync can English them. Also fixes a README top that showed five labels and no numbers on a phone. Suite 411 to 417. |
| **v3.9.0** | **A Codex thread whose cwd was a shared parent injected an unrelated project's plan on every hook fire** (closes #212, reported by @webwww123). Resolution was cwd relative with no notion of a thread, so the shared parent's pointer was the only one the hook could see. Adds `PWF_PLAN_ROOT` for an absolute plan root binding, which a cwd relative `PLAN_ID` slug structurally could not express, and refuses to inject when the cwd is ambiguous rather than guessing. Verifying the report exposed that `PLANNING_DISABLED=1` was inoperative on eleven of thirteen install routes, that the Stop hook could never find its script on six hosts, and that eight shipped PowerShell scripts could not be parsed by Windows PowerShell 5.1 at all, leaving Cursor injection and both Chinese variants' `init-session` dead on Windows. Also closes #211 (a provider error queued another request into the same failing provider, and the Pi status bar stopped tracking the plan after approval) and #210 (injection determinism now asserted, five routes normalized). Suite 311 to 411. |
| **v3.8.2** | **Session recovery silently found nothing for any project path containing a dot, a space, or any other non-alphanumeric character** (closes #209, reported by @seathatflowsinourveins). Three copies of `session-catchup.py` still folded only `/`, `\` and `:`, and one of them is the copy every `/plugin install` runs on Linux, macOS and Git Bash. Against a real store holding 89 sessions the shipped resolver produced 0 bytes where the fix produces 11336 and recovers 166 messages. Folding now counts UTF-16 code units, so emoji folder names resolve too, and a per-session `cwd` filter stops two projects that fold to one directory name from reading each other's transcripts. One vector table now runs across every copy, so this drift cannot come back. Suite at 311. |
| **v3.8.1** | **Pi extension: plan resolution no longer depends on the live shell cwd** (closes #208, reported by @fd44fdg). An agent that cd'd into a subdirectory lost the plan, recitation went dark, and the "No task_plan.md found" warning fired on every write. Resolution now anchors on the nearest ancestor with planning state, bounded by the `.git` repository boundary, with slug-validation and containment parity with the sh resolver; every injection states which plan it resolved (`plan: `), making slug-over-root shadowing visible. Also: `init-session` heredocs never carried the v3.8.0 Next Step section; all copies fixed with an output-level regression test. Gated by an Opus adversarial pass plus a five-lens Sonnet reliability fleet. |
| **v3.8.0** | **The Stop hook never fired on macOS or Linux** (a dead install-path fallback stacked on PowerShell-first dispatch), and **session recovery searched a project directory that does not exist** for POSIX or underscore project paths; both fixed with tests that execute the hooks end to end. Opt-in structure-aware injection (`PWF_INJECT=smart`) keeps the active phase and decision journal in the window late in long plans. Next Step pointer in the templates, tool-result outcomes in session catchup, macOS CI leg plus a BSD-userland simulation harness, `resolve-plan-dir.ps1` parity with fail-closed containment, UTF-8-safe ledger truncation, pinned line endings, and a rebuilt README with honest benchmark charts. Suite at 301. |
| **v3.7.0** | **Agent Skills standard layout ships in-tree**: `.agents/skills/planning-with-files/` carries the full canonical surface, so tools that read the standard path natively (Zed, Amp, Warp, Devin, Antigravity, Gemini CLI, Cursor) discover the current skill from a plain `git clone`. Locked into the 18-entry parity set; `plan-doctor.sh` now ships in every synced IDE folder. |
> The README is long; the above is its first 40000 characters. Full content: https://github.com/OthmanAdi/planning-with-files